ACE ROBOTICS Open-Sources Kairos-HomeWorld , Enabling Fully Interactive Whole-Home 3D Scene Generation from a Single Prompt
- Written by Telegraph Magazine
- Kairos-HomeWorld is purpose built for embodied intelligence and represents the first unified framework capable of generating a complete, fully interactive home environment from a single text prompt.
- Extending indoor scene generation beyond individual rooms, it enables whole-home simulation in which every object is fully manipulable within an integrated simulation engine.
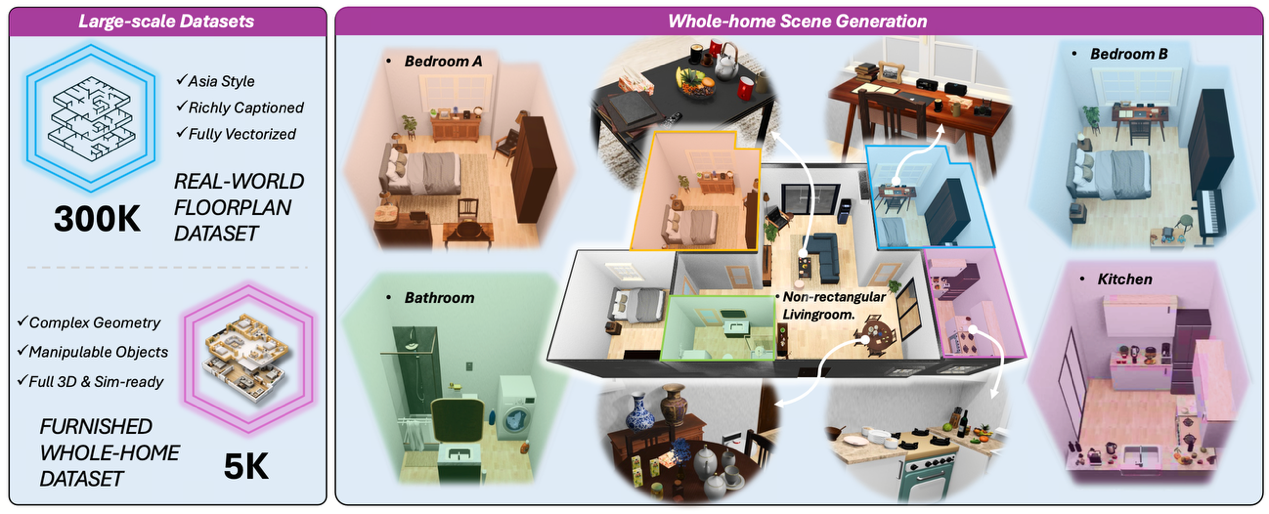
- Kairos-HomeWorld employs a four-stage hierarchical architecture encompassing floorplan generation, 2D-to-3D lifting, recursive refinement, and manipulable object placement. This approach enables the production of globally coherent, physically accurate, and simulation-ready scenes. Each environment contains more than 15 manipulable objects and achieves a Footprint Object Density of 4.16, the highest among compared methods.
- The accompanying open-source dataset is purpose-built for Chinese households, pairing 300,000 real residential floor plans with 5,000 fully furnished, simulation-ready homes and 50,000 physics-enabled interactive object assets. Already deployed in ACE ROBOTICS' daily robot training, it significantly accelerates the simulation-to-reality transfer cycle.
The long-term vision for embodied intelligence is the home environment. However, residential settings are inherently diverse and highly personalized, requiring robots to be trained across a broad range of realistic and differentiated scenarios before they can reliably operate in even a single household. High-fidelity simulation offers the most practical pathway to achieving this at scale, yet existing approaches typically involve a trade-off: synthetic environments lack realism, while scanned real-world scenes offer limited interactivity. Kairos-HomeWorld, together with its accompanying dataset, is designed to bridge this gap, delivering both realistic and interactive environments within a unified framework.
A four-stage architecture for whole-home, object-level generation
Conventional approaches to indoor scene generation remain constrained to single-room outputs, often exhibiting weak global consistency, frequent physical inaccuracies, and limited or no interactivity. Kairos-HomeWorld takes a fundamentally different approach. It decomposes whole-home generation into a structured, four-stage process, redefining the underlying architectural paradigm from the ground up.
Stage 1 — Floor Plan Generation. A K-D tree-based approach translates real-world floor plans into a hierarchical text representation that can be efficiently processed by large language models (LLMs). This method mitigates common issues in conventional layout generation, including room overlaps and fragmented topologies, resulting in more coherent and structurally consistent spatial configurations.
Stage 2 — 2D-to-3D Lifting & Furniture Layout Generation. A "top-down global initialization combined with a first-person detail walkthrough" approach anchors the process to the 3D building shell generated in Stage 1. This methodology mitigates the geometric drift commonly associated with conventional 2D-to-3D lifting techniques, enabling more stable and spatially consistent scene generation.
Stage 3 — Recursive Refinement. A fine-tuned vision-language model performs iterative validation and correction, automatically identifying and resolving physical inconsistencies, such as obstructed doorways or object collisions. This recursive process materially reduces spatial errors, achieving among the lowest reported furniture-collision rates in the industry.
Stage 4 — Manipulable Object Placement. A surface-centric placement algorithm assigns each object detailed physical properties, including material composition, density, friction, and structural support relationships. Each generated scene incorporates an average of more than 15 manipulable objects and achieves a Footprint Object Density (FOD) of 4.16, a metric reflecting the concentration of items across furniture surfaces. All objects are natively compatible with simulation engines, enabling direct interaction for tasks such as grasping, movement, and stacking.
The resulting environments move beyond "viewable but not actionable" outputs. Their coherent spatial structure enables seamless, continuous navigation across multiple rooms, while objects embedded with realistic physical properties allow robots to simulate complex household tasks end-to-end. Taken together, this approach addresses key limitations in existing data pipelines, resolving the scarcity of high-quality 3D simulation data, the lack of realism in synthetic environments, and the limited interactivity of scanned scenes within a single unified framework.
The dataset: 300,000 real floor plans, 5,000 fully interactive homes, built for Chinese households
ACE ROBOTICS and CUHK are open-sourcing a dataset of 300,000 structurally annotated residential floor plans, sourced from real-world listings and processed through a multi-stage automated pipeline. The pipeline vectorizes and labels key spatial elements, including door and window positions, room geometry, functional zoning, and connectivity. By comparison, widely used benchmarks such as RPLAN and ResPlan contain approximately 80,000 and 17,000 floor plans, respectively, underscoring the scale and comprehensiveness of the Kairos-HomeWorld dataset.
Building on this foundation, the dataset also includes 5,000 fully furnished residential environments, each featuring a complete furniture layout and an average of more than 15 physics-enabled, manipulable objects, powered by the PhysX-Omni model. All assets are sim-ready and can be directly imported into a simulation engine, enabling immediate use in interactive training scenarios.
Most existing open indoor-scene datasets are centered on North American and European residential formats, typically featuring open-plan kitchens, the absence of service balconies, and layouts and design elements that capture only a narrow segment of global housing. As a result, robots trained on these datasets often exhibit limited transferability when deployed in environments outside their scope. Kairos-HomeWorld 's dataset is purpose-built for Chinese households, with deliberate coverage of historically under-represented housing typologies. It spans a wide range of unit sizes, from approximately 30 m² (around 320 sq ft) studio apartments to residences exceeding 200 m² (approximately 2,150 sq ft). The dataset accurately reflects key architectural features common in these settings, including north-south cross-ventilated layouts, enclosed kitchens, dedicated service balconies, wet-and-dry-separated bathrooms, and entryway storage, as well as the irregular room configurations often found in older housing stock.
The dataset is being openly released to both academic and industry communities. Going forward, the team plans to expand its scope to include additional regions, interior styles, and interaction scenarios, further lowering barriers to real-world-ready training for embodied intelligence.
See it in action: one prompt to a fully interactive home
Kairos-HomeWorld runs the full end-to-end pipeline, from initial text input to a fully interactive home environment, delivering global spatial consistency, physical realism, and seamless interactivity from a single prompt.
The system begins with a single-line prompt: "Generate a 90 m² (approximately 970 sq ft) two-bedroom apartment in neo-Chinese style." Leveraging real floor plan data and its K-D tree representation, Kairos-HomeWorld first constructs an empty spatial layout aligned with real-world living patterns, incorporating cross-ventilation and well-defined functional zoning. Building on this foundation, a hierarchical "global layout plus first-person detail" approach furnishes the environment with stylistic coherence, while a PhysX-Omni rendering pass assigns full physical properties to all surfaces and objects, including articulated behavior, ensuring the scene is fully interactive and sim-ready.
A single natural-language instruction, "tidy the whole home", is decomposed by the robot into a variety of discrete sub-tasks, executed sequentially along a complete navigation path spanning the living room, bedrooms, kitchen, bathroom, and dining area. The robot recognizes objects, plans efficient routes, and performs precise manipulation tasks, including articulated-object interactions for opening refrigerator and cabinet doors, fluid interactions for pouring laundry detergent, soft-body interactions for drawing curtains, irregular-object interactions for grasping apples, and gravity-based physical interactions for placing snacks.
Conventional simulation environments typically support navigation-focused training in isolation. By contrast, Kairos-HomeWorld integrates globally consistent spatial structures with objects that embody realistic physical properties. This enables robots to interact naturally with more than 15 object types, accurately modeling real-world dynamics such as collision, gravity, and friction, and to rehearse the full lifecycle of complex household tasks entirely within a virtual environment.
Across the industry, the same structural bottleneck, the scarcity of home-scale training data, is being addressed through multiple approaches. For example, Figure AI's collaboration with Brookfield focuses on collecting human activity data across more than 100,000 residential units. Kairos-HomeWorld addresses this challenge through on-demand synthetic generation, delivering scalable training environments enhanced with object-level physical realism, capabilities that real-world data capture alone cannot fully provide.
In contrast, Kairos-HomeWorld delivers significantly lower costs and higher efficiency for household robot training. Powered by its world model, it can programmatically generate diverse Chinese home simulation scenes and physics-enabled interactive objects at scale.
Robots can complete a full range of household tasks training entirely within the virtual environment. New scene generation incurs near-zero marginal cost, eliminating substantial real-world testing expenses such as site operation and maintenance and furniture damage. Meanwhile, unconstrained by the limited stock of physical residential properties, it outperforms real-world data collection approaches in both training efficiency and scalable expansion.
Kairos-HomeWorld is already deployed in ACE ROBOTICS' embodied intelligence training workflows, enabling full-pipeline simulation of long-horizon household tasks, including cross-room navigation and multi-room tidying. By allowing robots to rehearse complete task sequences in a virtual environment, the platform significantly shortens the simulation-to-reality transfer cycle. This approach lowers barriers to developing embodied intelligence systems and supports the accelerated, large-scale deployment of home robotics, particularly within the Chinese market. Kairos-HomeWorld is now available on GitHub.Hashtag: #ACEROBOTICS
The issuer is solely responsible for the content of this announcement.
About ACE ROBOTICS
Equipping robots with intelligent "brains" and engaging "souls".
ACE ROBOTICS is a pioneering robotics company dedicated to advancing the field of embodied intelligence. Through breakthrough technological innovations and deep insights into embodied intelligence scenarios, we aim to empower robots with the ability to autonomously understand and explore the physical world, thereby accelerating their commercial implementation.
The company pioneered the ACE R&D paradigm and built a vision-based "environmental data engine, real-world cognition, embodied interaction generalization" technology chain. Using full spatiotemporal and multi-perspective environmental capture as its engine, along with Kairos 3.0 – China's first open-source and commercially applicable world model – plus the Embodied Foundation Model as its technical backbone, ACE ROBOTICS addresses core industry challenges such as data scarcity, common sense gaps, poor generalization, and limited versatility. Simultaneously, the company unveiled its flagship A1 Embodied Super Brain Module, accelerating the large-scale commercial deployment of embodied intelligence across diverse scenarios.
ACE ROBOTICS is both a technology pioneer and an ecosystem builder. Through strategic cooperation with top hardware manufacturers, cloud service providers, and vertical scenario partners, we have broken through the "model-hardware-scenario" industrial deadlock, providing standardized and customized solutions that are driving the development of China's embodied intelligence industry.


